Tip Of AI
Discover what you can do with AI
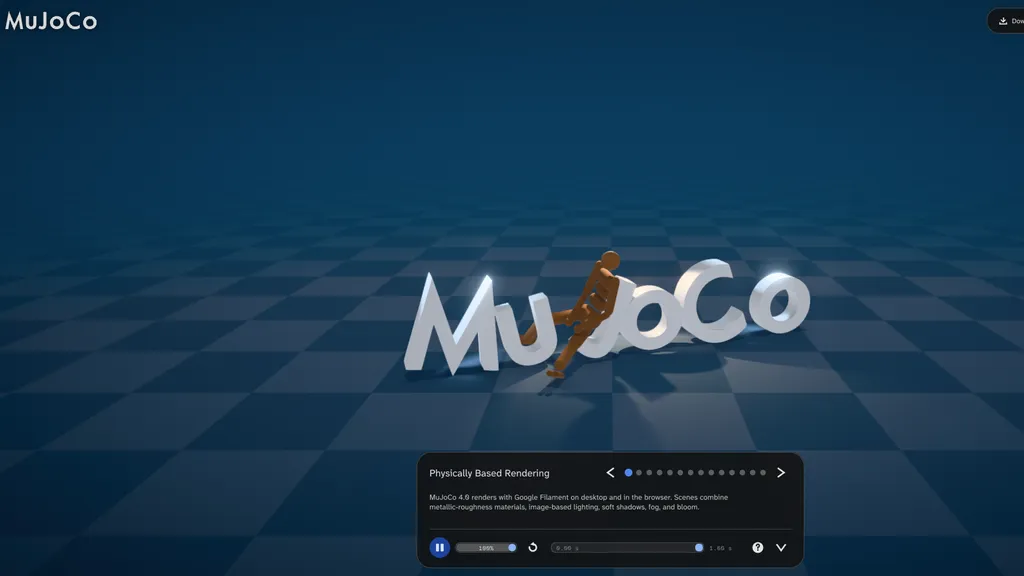
MuJoCo is an open source physics engine designed for research and development in robotics biomechanics graphics animation machine learning and physical simulation. The platform focuses on fast accurate simulation of articulated structures and contact rich environments where objects interact through collisions friction constraints and actuators. It is maintained by Google DeepMind and is available under the Apache 2.0 license which makes it suitable for academic research commercial development and educational use. Key features include generalized coordinate simulation inverse dynamics contact handling soft contacts joint limits dry friction equality constraints particle systems cloth rope and soft objects. MuJoCo supports motors cylinders muscles tendons and other actuator models. Users can select numerical solvers including Newton Conjugate Gradient and Projected Gauss Seidel as well as Euler and Runge Kutta integrators. Models are defined with the XML based MJCF format and compiled into efficient runtime structures. The software provides a C API Python bindings native visualization tools browser based WebAssembly experiences and Unity integration. It supports Windows Linux and macOS on common x86 64 and ARM 64 systems. MuJoCo is widely used for reinforcement learning optimal control system identification robot testing simulation visualization and sim to real research. The website also provides interactive demonstrations that can be explored directly in a browser without installation.